

September 2026
Thesis Project: TriplestarKB
A ROS package for deploying knowledge graphs onto robots
Tools & skills
- Knowledge Graphs
- devcontainers
- ROS
- Python
As part of my thesis project for the Robotics master’s programme at TU Delft, I developed TriplestarKB, a tool for integrating knowledge graphs with robotic systems.
The project focused on knowledge representation. In robotics, researchers often use knowledge graphs and OWL ontologies to model information about their systems. However, there was no standardized way to connect these knowledge graphs with the rest of the ROS ecosystem.
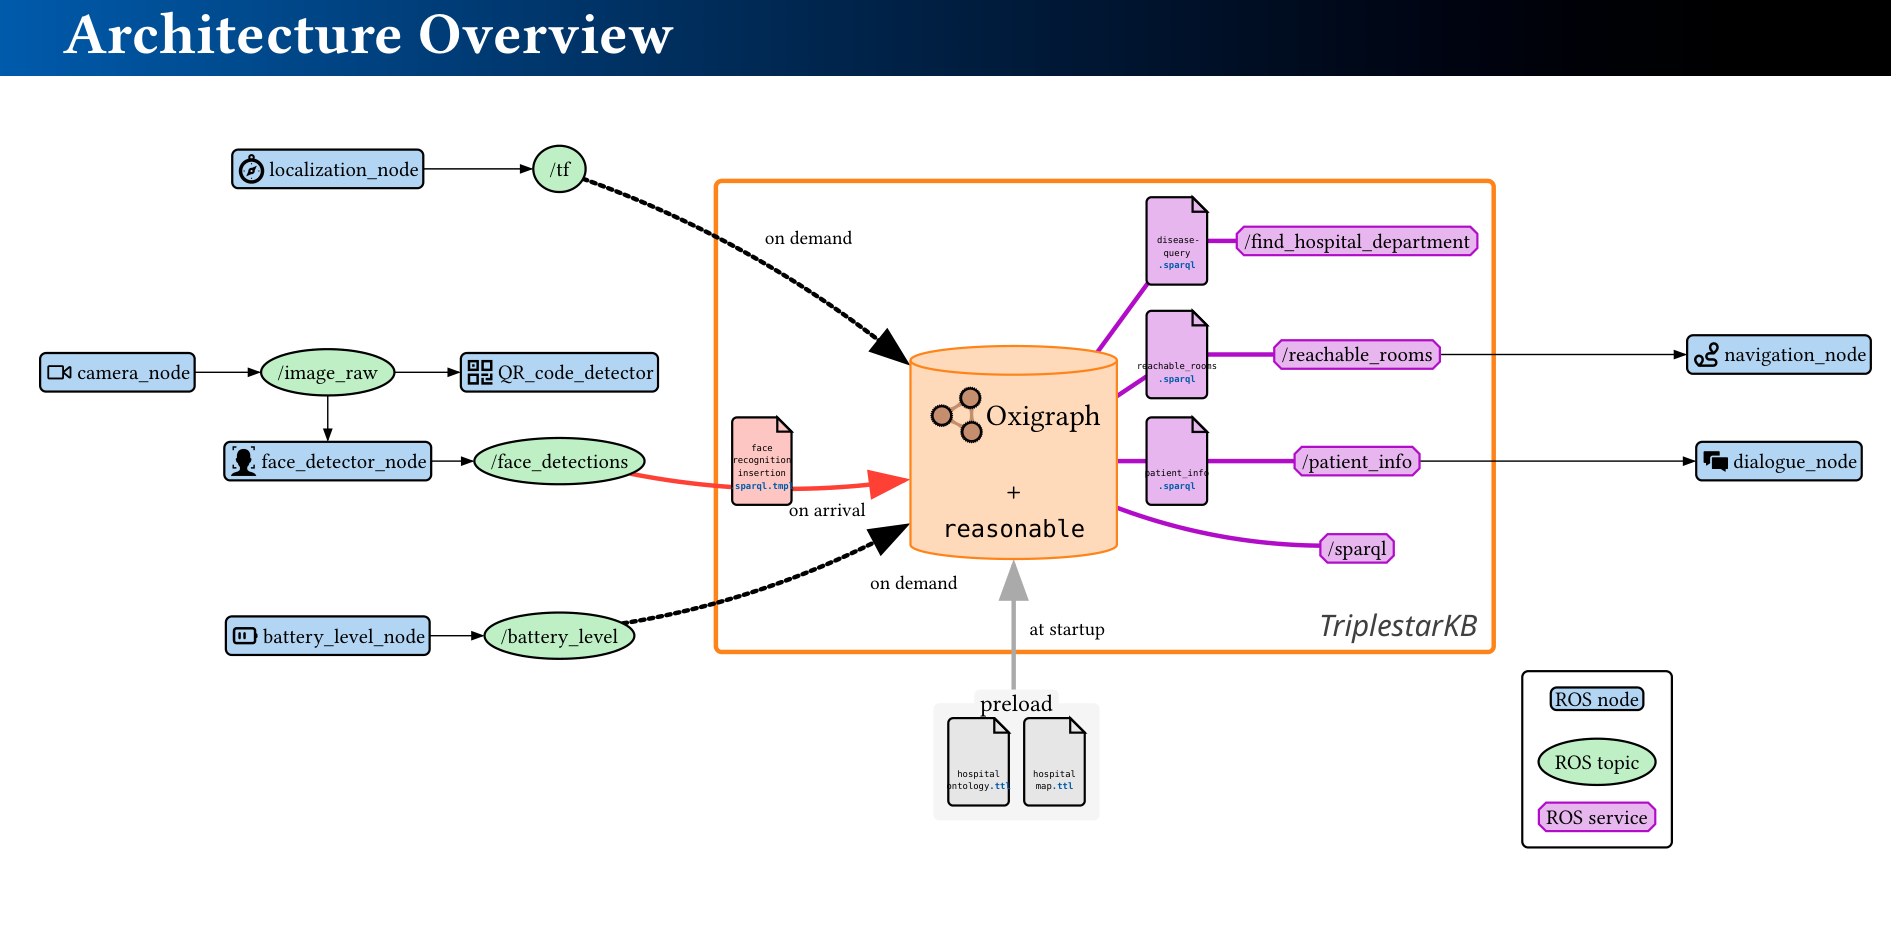
To address this gap, I built TriplestarKB as a ROS package that bundles the high-performance, Rust-based RDF triplestore Oxigraph. It also provides a translation layer between ROS and RDF data types, along with declarative configuration for storing and querying ROS data through a knowledge-graph interface.
TriplestarKB gives ROS data richer semantic meaning by combining runtime observations with predefined ontologies and domain knowledge. This makes it possible to answer complex questions about a robotic system in an explainable way.
CAD models
Gallery